I was able to complete the calibration for just to stereo pair. This the final calibration values which was flashed on to eprom:
(calib_depthai3.8.0) nvidia@ubuntu:~/gits/depthai$ python3.9 ../depthai-core/examples/python/Calibration/calibration_dump.py
Is EEPROM available: True
User calibration: {
"batchName": "",
"batchTime": 1717298050,
"boardConf": "IR-C00M00-00",
"boardCustom": "",
"boardName": "DD2090",
"boardOptions": 0,
"boardRev": "R7M1E7",
"cameraData": [
[
2,
{
"cameraType": 0,
"distortionCoeff": [
8.899492263793945,
2.2330410480499268,
-0.001545691629871726,
0.0011179590364918113,
-18.49042510986328,
8.572552680969238,
3.2359917163848877,
-19.242515563964844,
0.0,
0.0,
0.0,
0.0,
0.0,
0.0
],
"extrinsics": {
"rotationMatrix": [
[
0.9999744296073914,
-0.007141453679651022,
0.0004001893394161016
],
[
0.0071447319351136684,
0.9999349117279053,
-0.008896827697753906
],
[
-0.000336627010256052,
0.00889945961534977,
0.9999603629112244
]
],
"specTranslation": {
"x": 6.0,
"y": 0.0,
"z": 0.0
},
"toCameraSocket": 1,
"translation": {
"x": 5.950736999511719,
"y": -0.007525868713855743,
"z": -0.029660549014806747
}
},
"height": 800,
"intrinsicMatrix": [
[
796.2322998046875,
0.0,
644.235595703125
],
[
0.0,
794.7193603515625,
401.5271301269531
],
[
0.0,
0.0,
1.0
]
],
"lensPosition": 0,
"specHfovDeg": 80.0,
"width": 1280
}
],
[
1,
{
"cameraType": 0,
"distortionCoeff": [
7.314711093902588,
7.089082717895508,
-0.00038487964775413275,
5.061671981820837e-05,
-22.6594181060791,
6.999828815460205,
8.060517311096191,
-23.390344619750977,
0.0,
0.0,
0.0,
0.0,
0.0,
0.0
],
"extrinsics": {
"rotationMatrix": [
[
0.0,
0.0,
0.0
],
[
0.0,
0.0,
0.0
],
[
0.0,
0.0,
0.0
]
],
"specTranslation": {
"x": 0.0,
"y": 0.0,
"z": 0.0
},
"toCameraSocket": -1,
"translation": {
"x": 0.0,
"y": 0.0,
"z": 0.0
}
},
"height": 800,
"intrinsicMatrix": [
[
798.0176391601562,
0.0,
655.2503662109375
],
[
0.0,
796.7785034179688,
399.33209228515625
],
[
0.0,
0.0,
1.0
]
],
"lensPosition": 0,
"specHfovDeg": 80.0,
"width": 1280
}
],
[
3,
{
"cameraType": 0,
"distortionCoeff": [
-10.458497047424316,
104.62010955810547,
0.0005981730646453798,
-0.0008816338959150016,
-50.37309265136719,
-10.494210243225098,
103.99183654785156,
-48.6142692565918,
0.0,
0.0,
0.0,
0.0,
0.0,
0.0
],
"extrinsics": {
"rotationMatrix": [
[
1.0,
0.0,
0.0
],
[
0.0,
1.0,
0.0
],
[
0.0,
0.0,
1.0
]
],
"specTranslation": {
"x": 10.0,
"y": 0.0,
"z": 0.0
},
"toCameraSocket": 1,
"translation": {
"x": 10.0,
"y": 0.0,
"z": 0.0
}
},
"height": 800,
"intrinsicMatrix": [
[
801.8607788085938,
0.0,
651.6859741210938
],
[
0.0,
802.0641479492188,
407.34967041015625
],
[
0.0,
0.0,
1.0
]
],
"lensPosition": 0,
"specHfovDeg": 80.0,
"width": 1280
}
],
[
0,
{
"cameraType": 0,
"distortionCoeff": [
4.428467273712158,
12.631766319274902,
-0.0008713753195479512,
-0.0005999229615554214,
-24.348819732666016,
4.171751022338867,
13.42512321472168,
-24.945770263671875,
0.0,
0.0,
0.0,
0.0,
0.0,
0.0
],
"extrinsics": {
"rotationMatrix": [
[
-0.999979555606842,
0.0026230337098240852,
0.005833887029439211
],
[
-0.0026709451340138912,
-0.9999626278877258,
-0.008220034651458263
],
[
0.005812107585370541,
-0.008235448971390724,
0.9999492168426514
]
],
"specTranslation": {
"x": 3.0,
"y": 0.0,
"z": 0.0
},
"toCameraSocket": 1,
"translation": {
"x": 2.990255832672119,
"y": -0.047424495220184326,
"z": -0.06258359551429749
}
},
"height": 800,
"intrinsicMatrix": [
[
805.049072265625,
0.0,
643.1897583007812
],
[
0.0,
804.2926635742188,
363.5214538574219
],
[
0.0,
0.0,
1.0
]
],
"lensPosition": 0,
"specHfovDeg": 80.0,
"width": 1280
}
]
],
"deviceName": "",
"hardwareConf": "F0-FV00-BC000",
"housingExtrinsics": {
"rotationMatrix": [],
"specTranslation": {
"x": 0.0,
"y": 0.0,
"z": 0.0
},
"toCameraSocket": -1,
"translation": {
"x": 0.0,
"y": 0.0,
"z": 0.0
}
},
"imuExtrinsics": {
"rotationMatrix": [
[
0.0,
0.0,
0.0
],
[
0.0,
0.0,
0.0
],
[
0.0,
0.0,
0.0
]
],
"specTranslation": {
"x": 0.0,
"y": 0.0,
"z": 0.0
},
"toCameraSocket": -1,
"translation": {
"x": 0.0,
"y": 0.0,
"z": 0.0
}
},
"miscellaneousData": [],
"productName": "OAK-FFC-4P",
"stereoEnableDistortionCorrection": true,
"stereoRectificationData": {
"leftCameraSocket": 1,
"rectifiedRotationLeft": [
[
0.9999867677688599,
-0.0012646785471588373,
-0.00498428288847208
],
[
0.0012867969926446676,
0.9999893307685852,
0.004436938092112541
],
[
0.004978618584573269,
-0.00444329297170043,
0.999977707862854
]
],
"rectifiedRotationRight": [
[
0.9999538660049438,
-0.008450312539935112,
-0.004572649486362934
],
[
0.00842992588877678,
0.9999545216560364,
-0.004459455609321594
],
[
0.004610125441104174,
0.004420702811330557,
0.9999796152114868
]
],
"rightCameraSocket": 2
},
"stereoUseSpecTranslation": false,
"version": 7,
"verticalCameraSocket": -1
}
Factory calibration: {
"batchName": "",
"batchTime": 1717298050,
"boardConf": "IR-C00M00-00",
"boardCustom": "",
"boardName": "DD2090",
"boardOptions": 0,
"boardRev": "R7M1E7",
"cameraData": [],
"deviceName": "",
"hardwareConf": "F0-FV00-BC000",
"housingExtrinsics": {
"rotationMatrix": [],
"specTranslation": {
"x": 0.0,
"y": 0.0,
"z": 0.0
},
"toCameraSocket": -1,
"translation": {
"x": 0.0,
"y": 0.0,
"z": 0.0
}
},
"imuExtrinsics": {
"rotationMatrix": [
[
0.0,
0.0,
0.0
],
[
0.0,
0.0,
0.0
],
[
0.0,
0.0,
0.0
]
],
"specTranslation": {
"x": 0.0,
"y": 0.0,
"z": 0.0
},
"toCameraSocket": -1,
"translation": {
"x": 0.0,
"y": 0.0,
"z": 0.0
}
},
"miscellaneousData": [],
"productName": "OAK-FFC-4P",
"stereoEnableDistortionCorrection": false,
"stereoRectificationData": {
"leftCameraSocket": 255,
"rectifiedRotationLeft": [
[
0.0,
0.0,
0.0
],
[
0.0,
0.0,
0.0
],
[
0.0,
0.0,
0.0
]
],
"rectifiedRotationRight": [
[
0.0,
0.0,
0.0
],
[
0.0,
0.0,
0.0
],
[
0.0,
0.0,
0.0
]
],
"rightCameraSocket": 255
},
"stereoUseSpecTranslation": true,
"version": 7,
"verticalCameraSocket": -1
}
(calib_depthai3.8.0) nvidia@ubuntu:~/gits/depthai$
this is output of calibration:
(calib_depthai3.8.0) nvidia@ubuntu:~/gits/depthai$ python3.9 calibrate.py -nx 13 -ny 7 -s 4.44 -ms 3.3 -dsb down middle -m process -brd OAK-FFC-4P-4Cam.json
[OK] OpenCV version 4.5.5 is correct.
Cam: left and focus: False
Cam: right and focus: False
Using dataset path: dataset
Starting image processing
<------------Calibrating left ------------>
INTRINSIC CALIBRATION
Filtering corners
5
Pose estimation 0, 0.0019376277923583984s
Pose estimation 1, 0.0015404224395751953s
Pose estimation 2, 0.001538991928100586s
Pose estimation 3, 0.0008802413940429688s
Pose estimation 4, 0.0008955001831054688s
Pose estimation 5, 0.0009326934814453125s
Pose estimation 6, 0.0009427070617675781s
Pose estimation 7, 0.0008056163787841797s
Pose estimation 8, 0.0009970664978027344s
Pose estimation 9, 0.001528024673461914s
Pose estimation 10, 0.0015642642974853516s
Pose estimation 11, 0.0008287429809570312s
Pose estimation 12, 0.0008294582366943359s
Pose estimation 13, 0.0015192031860351562s
Pose estimation 14, 0.0008711814880371094s
Pose estimation 15, 0.0008361339569091797s
Pose estimation 16, 0.0015141963958740234s
Pose estimation 17, 0.0016016960144042969s
Pose estimation 18, 0.0029456615447998047s
Pose estimation 19, 0.0008873939514160156s
Pose estimation 20, 0.0016505718231201172s
Pose estimation 21, 0.0009431838989257812s
Pose estimation 22, 0.0008652210235595703s
Pose estimation 23, 0.0009291172027587891s
Pose estimation 24, 0.0008456707000732422s
Pose estimation 25, 0.0014584064483642578s
Pose estimation 26, 0.0008363723754882812s
Pose estimation 27, 0.0009274482727050781s
Pose estimation 28, 0.0008563995361328125s
Pose estimation 29, 0.0008716583251953125s
Pose estimation 30, 0.0008559226989746094s
Pose estimation 31, 0.0008647441864013672s
Pose estimation 32, 0.0008687973022460938s
Pose estimation 33, 0.0008919239044189453s
Pose estimation 34, 0.0008909702301025391s
Overall pose estimation 0.04079318046569824s
Use DEFAULT model
Filtering 0.8491780757904053s
Filtering takes: 2.0718541145324707
Use DEFAULT model
Each filtering 0.846477746963501
Each calibration 0.8908121585845947
Each filtering 0.8455061912536621
Each calibration 1.178589105606079
Each filtering 0.8460679054260254
Each calibration 0.32723450660705566
Whole procedure: 4.936138153076172
Reprojection error of left: 0.305878996290839
<------------Calibrating right ------------>
INTRINSIC CALIBRATION
Filtering corners
5
Pose estimation 0, 0.0012814998626708984s
Pose estimation 1, 0.0008831024169921875s
Pose estimation 2, 0.0008587837219238281s
Pose estimation 3, 0.0008745193481445312s
Pose estimation 4, 0.0008897781372070312s
Pose estimation 5, 0.0007085800170898438s
Pose estimation 6, 0.0010097026824951172s
Pose estimation 7, 0.0008082389831542969s
Pose estimation 8, 0.0008797645568847656s
Pose estimation 9, 0.0008649826049804688s
Pose estimation 10, 0.0015344619750976562s
Pose estimation 11, 0.0009305477142333984s
Pose estimation 12, 0.001501321792602539s
Pose estimation 13, 0.0009100437164306641s
Pose estimation 14, 0.0008392333984375s
Pose estimation 15, 0.0008928775787353516s
Pose estimation 16, 0.0022585391998291016s
Pose estimation 17, 0.003065347671508789s
Pose estimation 18, 0.0014908313751220703s
Pose estimation 19, 0.0008027553558349609s
Pose estimation 20, 0.001528024673461914s
Pose estimation 21, 0.0008602142333984375s
Pose estimation 22, 0.0015158653259277344s
Pose estimation 23, 0.0015752315521240234s
Pose estimation 24, 0.0009088516235351562s
Pose estimation 25, 0.0009076595306396484s
Pose estimation 26, 0.0008387565612792969s
Pose estimation 27, 0.0008301734924316406s
Pose estimation 28, 0.0015532970428466797s
Pose estimation 29, 0.0009174346923828125s
Pose estimation 30, 0.0006954669952392578s
Pose estimation 31, 0.0008234977722167969s
Pose estimation 32, 0.0008385181427001953s
Pose estimation 33, 0.0016052722930908203s
Pose estimation 34, 0.0008778572082519531s
Overall pose estimation 0.04041123390197754s
Use DEFAULT model
Filtering 0.8698921203613281s
Filtering takes: 2.0418155193328857
Use DEFAULT model
Each filtering 0.8735194206237793
Each calibration 0.7952096462249756
Each filtering 0.8759410381317139
Each calibration 0.37127685546875
Each filtering 0.870154619216919
Each calibration 0.5032410621643066
Whole procedure: 4.2906858921051025
Reprojection error of right: 0.28276939250045163
<-------------Extrinsics calibration of right and left ------------>
Use DEFAULT model
Epipolar error is 0.29641851453754287
Printing Extrinsics res...
[[ 9.99974419e-01 -7.14145383e-03 4.00189345e-04]
[ 7.14473209e-03 9.99934898e-01 -8.89682758e-03]
[-3.36627008e-04 8.89945924e-03 9.99960342e-01]]
[[ 5.95073714]
[-0.00752587]
[-0.02966055]]
Euler angles in XYZ [0.50990821 0.01928731 0.4093665 ] degs
<-------------Epipolar error of right and left ------------>
Epipolar error 0.29641851453754287
Reprojection error threshold -> 1.1111111111111112
left Reprojection Error: 0.305879
/home/nvidia/gits/depthai/calibrate.py:1193: DeprecationWarning: Conversion of an array with ndim > 0 to a scalar is deprecated, and will error in future. Ensure you extract a single element from your array before performing this operation. (Deprecated NumPy 1.25.)
calibration_handler.setDistortionCoefficients(stringToCam[camera], cam_info['dist_coeff'])
Reprojection error threshold -> 1.1111111111111112
right Reprojection Error: 0.282769
/home/nvidia/gits/depthai/calibrate.py:1232: DeprecationWarning: Conversion of an array with ndim > 0 to a scalar is deprecated, and will error in future. Ensure you extract a single element from your array before performing this operation. (Deprecated NumPy 1.25.)
calibration_handler.setCameraExtrinsics(stringToCam[camera], stringToCam[cam_info['extrinsics']['to_cam']], cam_info['extrinsics']['rotation_matrix'], cam_info['extrinsics']['translation'], specTranslation)
Flashing Calibration data into
EEPROM VERSION being flashed is -> 7
EEPROM VERSION being flashed is -> 7
py: DONE.
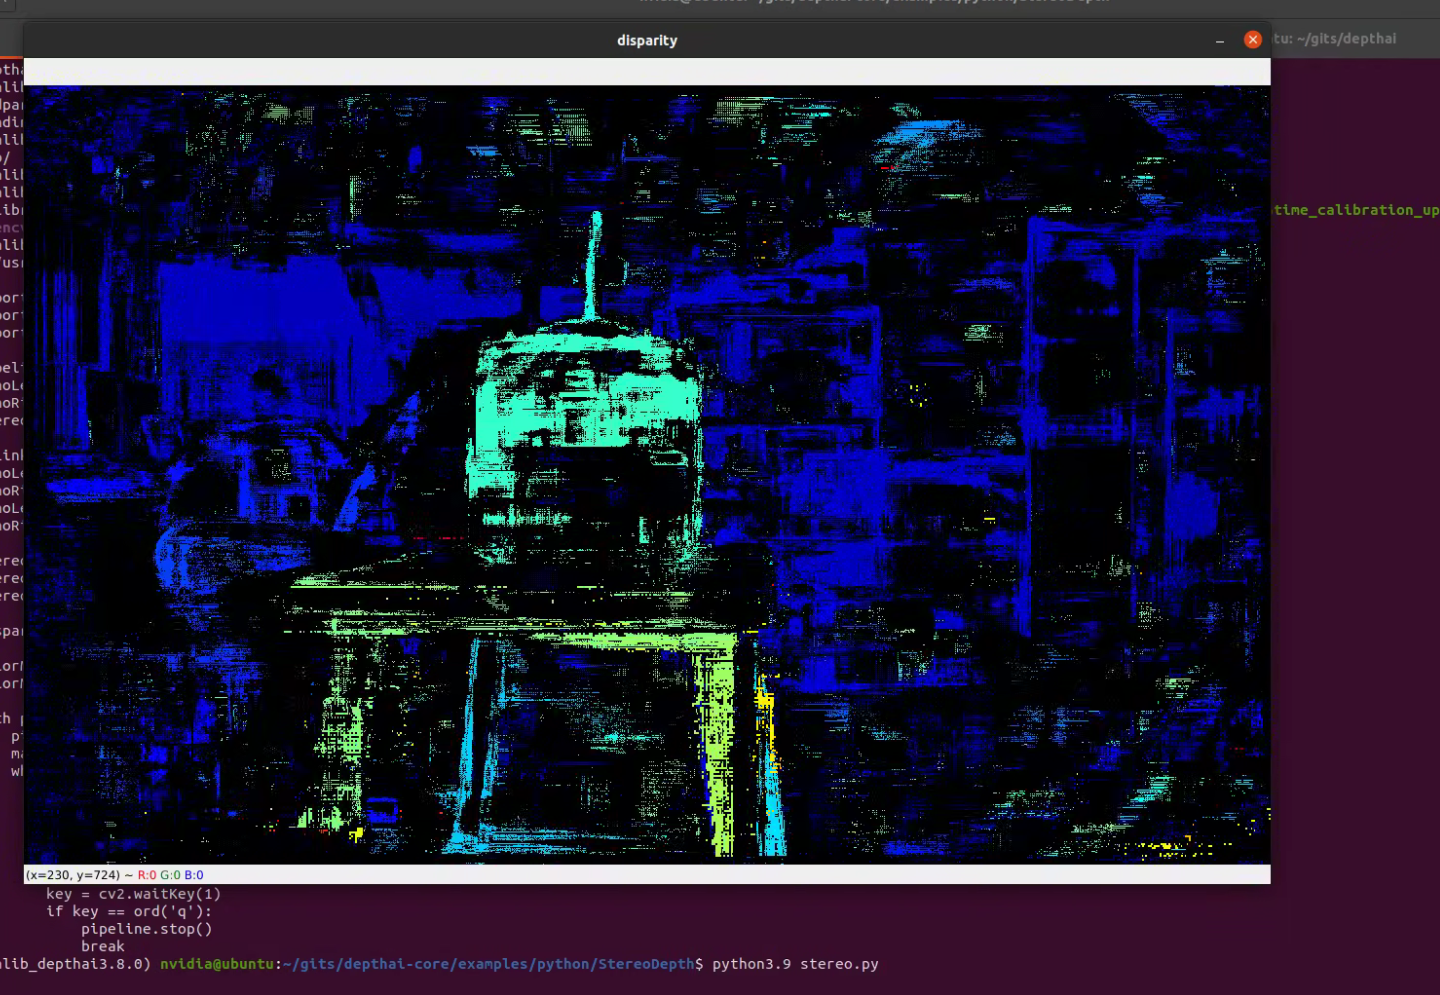
this is the stereo.py output:
Now in the actual usecase.I want to use 640x400 image output for stereo and as said in your documention & as required for my usecase i need mono stream output. So if i move to this settings. should i recalibrate with mono in json? or proceeding with these calibration information?