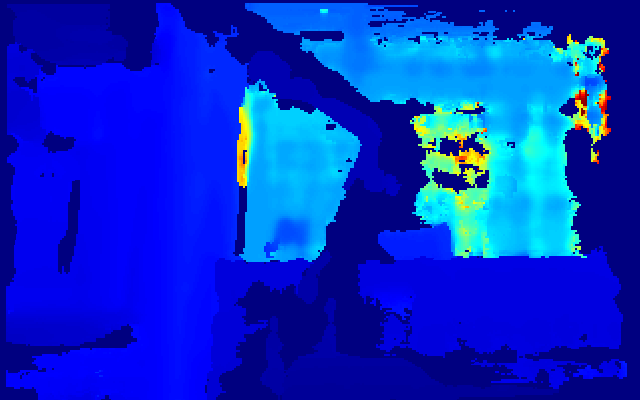
Hi,
I am trying to calculate the depth image using the disparity map, by using the formula:
z = fx * baseline / disparity
I do get my calculated depth map to look like the depth map coming from oak-d (see attached images) but there seems to be a scaling issue. Picking out a random pixel I get: disparity: 1123, depth: 1626 and depth calculated : 18.93. From reading the calibration my focal length is 283.42 and my baseline 75mm.
What am I doing wrong? Thanks
def to_cmap(frame: np.ndarray):
max_ = np.max(frame)
min_ = np.min(frame)
if max_ - min_ == 0:
return np.zeros_like(frame)
frame = (frame - min_) / (max_ - min_) * 255
frame = frame.astype(np.uint8)
frame = cv2.applyColorMap(frame, cv2.COLORMAP_JET)
return frame
def disp_2_depth(disparity: np.ndarray, baseline: float, fx :float):
depth = np.where(disparity == 0, 0, fx * baseline / disparity)
return depth
def main():
print(dai.Device.getAllAvailableDevices())
dev = dai.Device("192.168.178.120")
calib = dev.readCalibration()
baseline = calib.getBaselineDistance()
baseline *= 10 # mm
print(baseline)
intrinsics = np.array(calib.getCameraIntrinsics(dai.CameraBoardSocket.CAM_C, IMG_WIDTH, IMG_HEIGHT))
fx = intrinsics[0, 0].item()
fy = intrinsics[1, 1].item()
print(f"fx: {fx}, fy: {fy} Pixel")
hfov = calib.getFov(dai.CameraBoardSocket.CAM_C)
fx_calc = IMG_WIDTH * 0.5 / tan(hfov * 0.5 * pi / 180)
print(f"focal length: {fx_calc} - using fx from intrinsics")
pipeline = dai.Pipeline(dev)
left_cam = pipeline.create(dai.node.Camera).build(dai.CameraBoardSocket.CAM_B)
right_cam = pipeline.create(dai.node.Camera).build(dai.CameraBoardSocket.CAM_C)
right = right_cam.requestOutput((IMG_WIDTH, IMG_HEIGHT), enableUndistortion=False)
left = left_cam.requestOutput((IMG_WIDTH, IMG_HEIGHT), enableUndistortion=False)
stereo = pipeline.create(dai.node.StereoDepth)
stereo.setDepthAlign(dai.CameraBoardSocket.CAM_C)
stereo.setDefaultProfilePreset(dai.node.StereoDepth.PresetMode.DEFAULT)
stereo.setSubpixel(False)
stereo.setExtendedDisparity(False)
print(stereo.initialConfig)
left.link(stereo.left)
right.link(stereo.right)
queue = {
"disparity": stereo.disparity.createOutputQueue(),
"depth": stereo.depth.createOutputQueue(),
}
pipeline.start()
x, y = 200, 200 # get values at some random pixels
while True:
disp = queue["disparity"].get()
depth = queue["depth"].get()
assert isinstance(disp, dai.ImgFrame)
assert isinstance(depth, dai.ImgFrame)
print(disp.getType(), disp.getCvFrame().dtype)
disp = disp.getCvFrame()
depth = depth.getCvFrame()
disp_px = disp / 8 # Converting to px
cv2.imshow("disp", to_cmap(disp))
cv2.imshow("depth", to_cmap(depth))
depth_calc = disp_2_depth(disp_px, baseline, fx)
print(f"disp: {disp[x, y]}, disp_px: {disp_px[x, y]}, depth: {depth[x, y]}, depth calc: {depth_calc[x, y]}")
cv2.imshow("depth calculated", to_cmap(depth_calc))
if cv2.waitKey(1) == ord("q"):
break
cv2.destroyAllWindows(
Disparity (coming from oak-d)
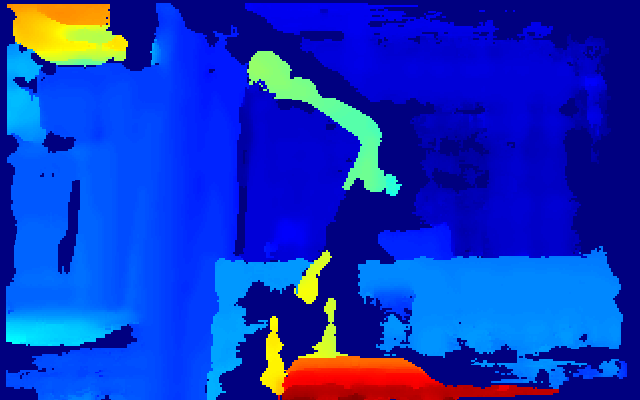
Depth (also from oak-d):
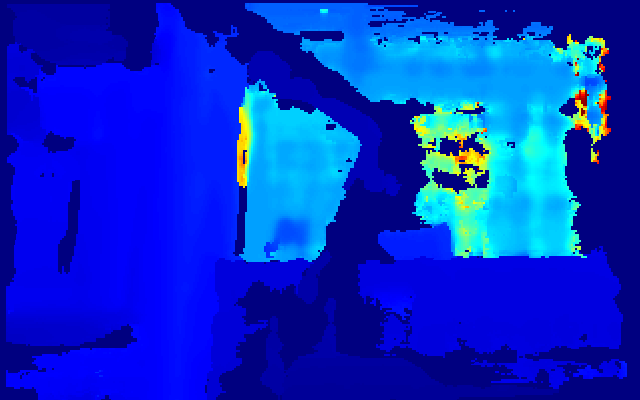
Depth calculated: